Player-1: Learning to Play
from
Synthetic Experience

Beyond watching demonstrations, with learning by playing.

Mingyu Ouyang1,* · Yiran Wang2,† · Siyuan Hu3 · Xingyilang Yin2 · Huiqiang Sun2 · Guangzhi Wang2 · Junfu Pu2 · Cheng Cheng2 · Honghao Chen2 · Ying Shan2 · Mike Zheng Shou1,‡ · Hwee Tou Ng1,‡

1 National University of Singapore2 ARC Lab, Tencent3 Nanyang Technological University

* Work done during internship at ARC Lab, Tencent† Project Lead‡ Co-corresponding Authors

See Player-1 in the Wild

1
FROM COMPUTER-USE AGENT TO GAME CONTROL

A few extensions let computer-use agents control games.

01 / ACTION SPACE

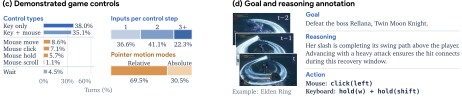
Extending the computer-use agent for games

From cursor positioning to camera control.

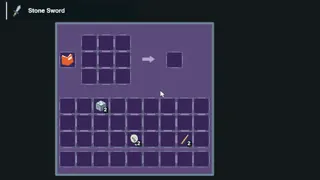
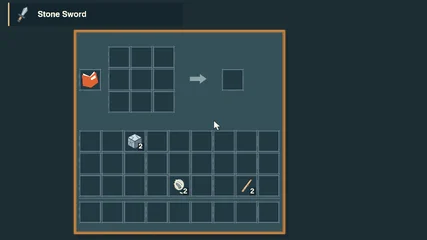
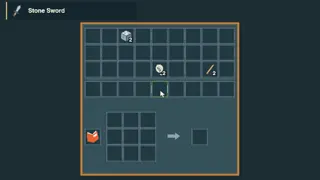
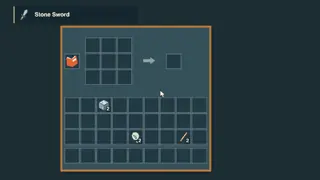
Left - Computer-use control:
Use absolute coordinates to move items in the inventory.

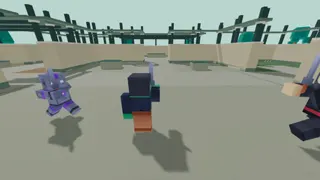
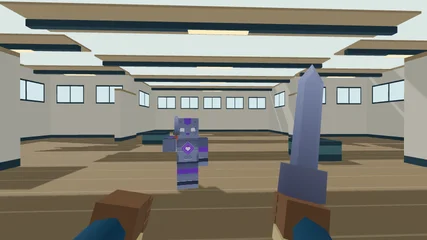
Right - Game control:
Relative mouse input turns the view to follow a flying bat.

2
FROM CONTROLS TO DEMONSTRATIONS

Curated gameplay demonstrations provide the starting point.

02 / SFT DATA

Demonstrations for supervised initialization

Curated gameplay data for aligned supervision.

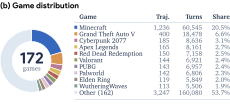
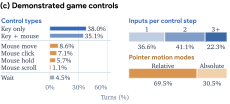
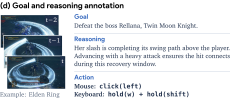
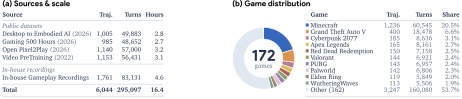
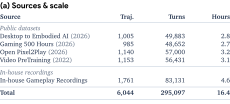
The collection comprises 6,044 trajectories from 172 games: 5,360 gameplay trajectories and 684 in-game UI trajectories. Recorded controls are mapped to the shared game control action space. Task instructions, reasoning, and keyboard-mouse actions make each step a supervised learning example.
3
FROM DEMONSTRATIONS TO PLAY

Player-1-Gym enables learning by playing with verifiable rewards.

03 / PLAYER-1-GYM

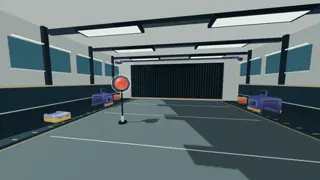
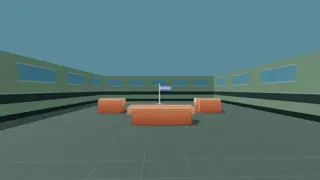
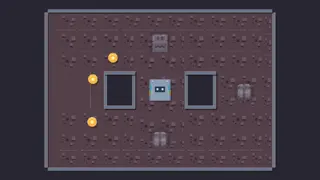
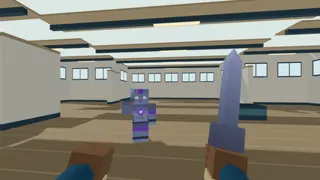
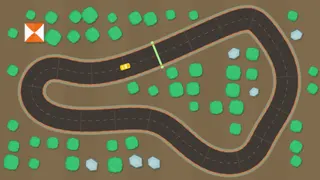
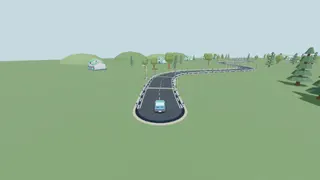
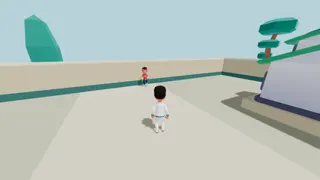
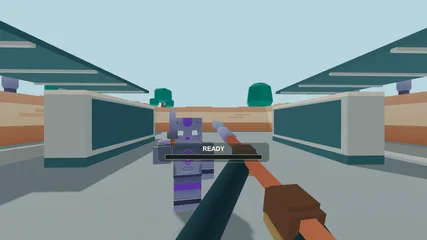
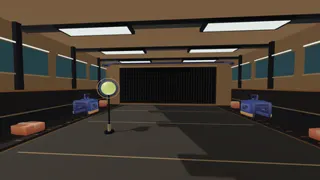
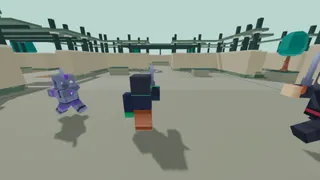
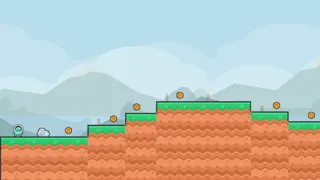
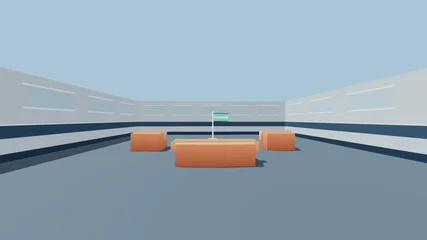
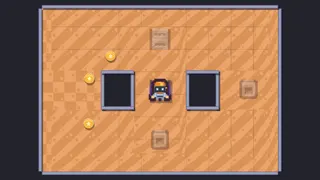
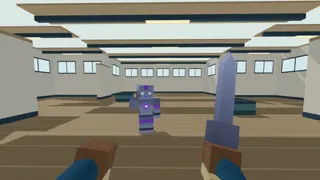
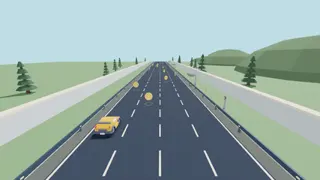
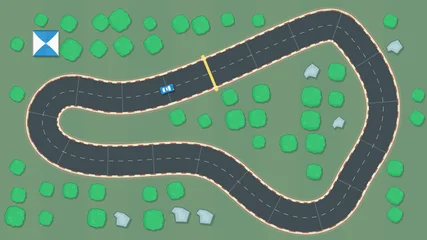
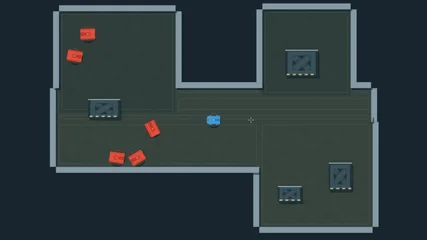
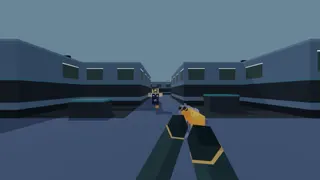
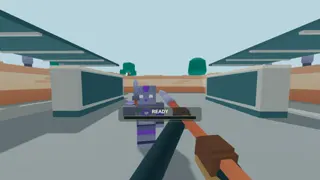
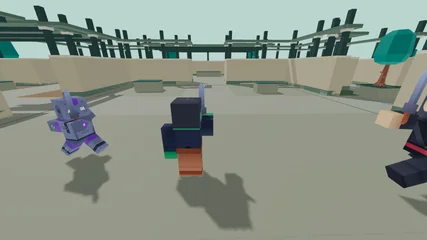
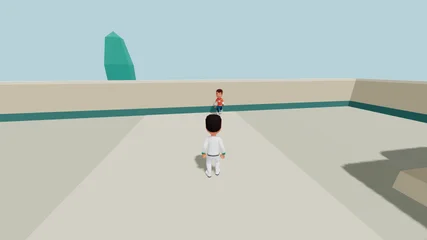
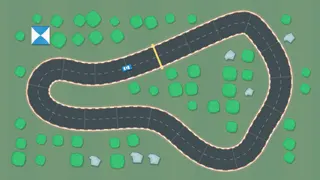
Explore Player-1-Gym environments

Shared control demands with diverse game mechanics.

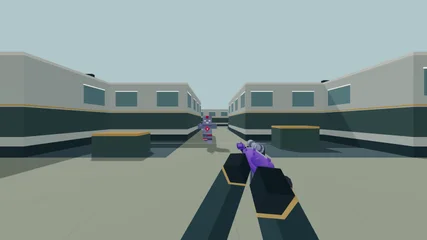
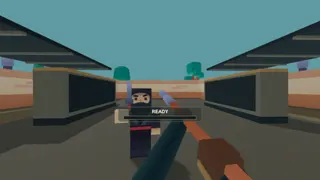
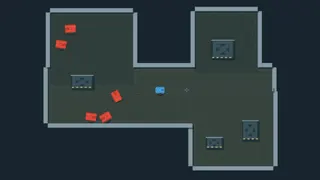
Each environment accepts keyboard and mouse actions and computes rewards directly from game state. Randomizing appearance, camera, scene, and control broadens the agent’s training experience.

Environment randomization

Let the learnt experience diverse.

Appearance
Colors, lighting, assets
Camera
Projection and viewpoint
Scene
Layouts, spawns, routes
Control
Look, move, drive, steer gains

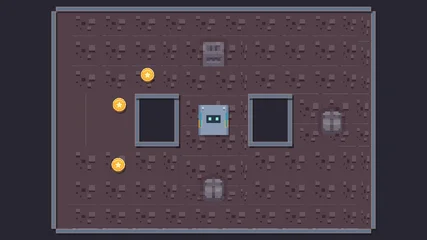
2D Collect & Dodge

2D Collect & Dodge: Original
2D Collect & Dodge: Appearance
2D Collect & Dodge: Appearance + Camera
2D Collect & Dodge: Appearance + Camera + Scene

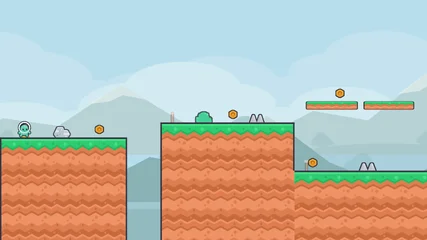
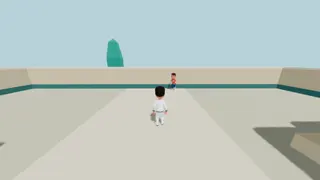
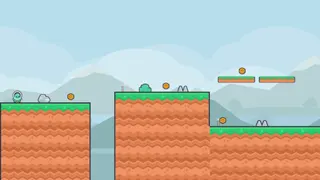
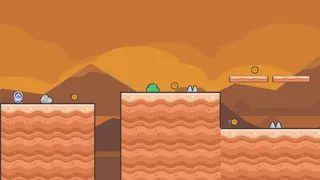
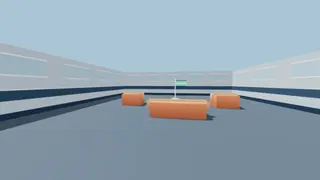
2D Platforming

2D Platforming: Original
2D Platforming: Appearance
2D Platforming: Appearance + Camera
2D Platforming: Appearance + Camera + Scene

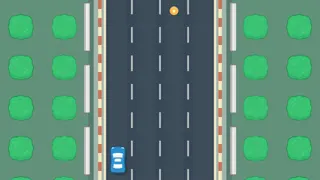
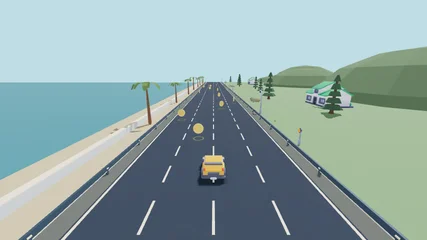
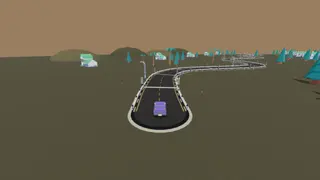
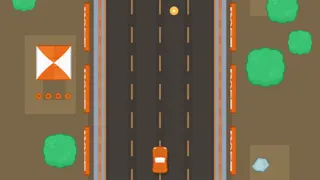
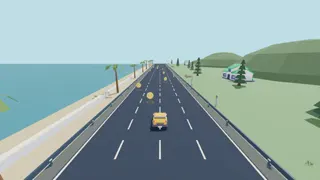
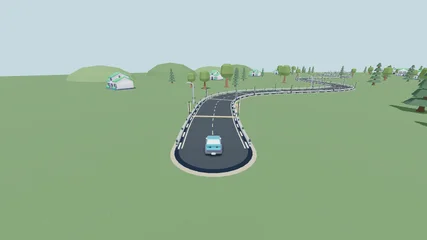
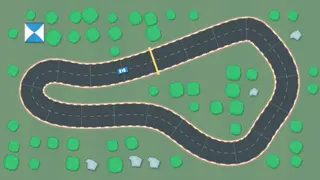
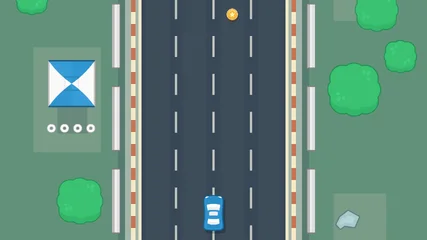
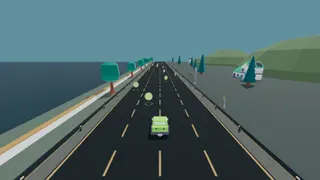
3D Lane Driving

3D Lane Driving: Original
3D Lane Driving: Appearance
3D Lane Driving: Appearance + Camera
3D Lane Driving: Appearance + Camera + Scene

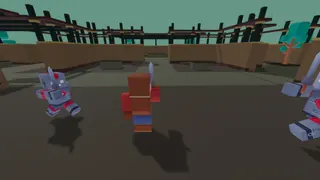
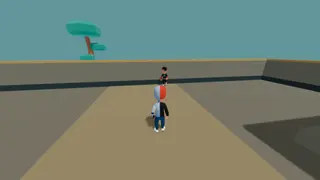
3D Chasing

3D Chasing: Original
3D Chasing: Appearance
3D Chasing: Appearance + Camera
3D Chasing: Appearance + Camera + Scene

LEARNING DYNAMICS

Reinforcement learning across sixteen worlds

Episode returns for 9B and 35B-A3B across sixteen training environments over 200 RL training steps
4
FROM EXPERIENCE TO HELD-OUT ENVIRONMENTS

Experience gained through play transfers to held-out environments.

04 / BENCHMARK & RESULTS

Experience that transfers

MINECRAFT · MINEDOJO-300 · PLAYER-1-9B task success after RL Player-1-9B: 38.33% task success after RL.

Player-1 learns through interaction in synthetic worlds, then transfers to games outside the RL training suite: From 10.54% after SFT to 38.33% after RL, a +27.79 percentage-point gain on the 300 tasks in MineDojo.

GameWAM, the strongest evaluated external baseline, reaches 12.63% under the paper's evaluation protocol.

PERFORMANCE

SFT improves, RL boosts

Base (Qwen3.5-9B/35B-A3B) → SFT → RL
01 / MINECRAFT

MineDojo-300

Explore cases ↓

Task success

ModelBaseSFTRL
9B9.21%10.54%38.33%
35B-A3B7.79%23.38%41.04%
02 / VIZDOOM

Mean scaled return*

ModelBaseSFTRL
9B0.29750.43610.6922
35B-A3B0.39120.56440.7236
03 / GAMEWORLD

Task progress

ModelBaseSFTRL
9B29.22%31.43%34.45%
35B-A3B33.49%34.60%38.79%

TRAJECTORIES

Recorded gameplay in Minecraft, ViZDoom, and GameWorld

Task / mapStepsOutcomeTrajectory
Loading trajectories…

Cite this work

BibTeX
@misc{ouyang2026player1,
  title = {Player-1: Learning to Play from Synthetic Experience},
  author = {Ouyang, Mingyu and Wang, Yiran and Hu, Siyuan and Yin, Xingyilang and Sun, Huiqiang and Wang, Guangzhi and Pu, Junfu and Cheng, Cheng and Chen, Honghao and Shan, Ying and Shou, Mike Zheng and Ng, Hwee Tou},
  year = {2026}
}
01 / 16

2D Aiming

Ready to play